
KK 2.1.5 Flight Control Board
5.0Editor score
Purpose-built VTOL and V-tail support
Self-leveling and acrobatic flight modes
Designed for customizable hobby builds
This guide compares flight controllers for hybrid VTOL and VTOL drones, including firmware support, sensors, connectivity, mounting, and expansion options.
Flight controllers for hybrid VTOL and VTOL drones must coordinate fixed-wing aerodynamics, vertical thrust, receiver inputs, and often autonomous flight modes. A capable controller should deliver stable transitions, dependable sensor data, flexible outputs, and enough connectivity for GPS, telemetry, ESCs, and other onboard equipment. The right choice depends heavily on aircraft design, firmware, and pilot experience.
This guide compares ten controllers using the supplied product information, focusing on processor platform, sensor suite, communication options, supported firmware, physical dimensions, mounting pattern, and intended aircraft type. It includes purpose-built VTOL boards, universal autopilot controllers, fixed-wing-oriented units, and compact flight-controller-and-ESC stacks suitable for custom multirotor or hybrid builds.
The selections show how the category ranges from lightweight hobby boards to advanced open-source autopilot platforms. The top recommendations balance VTOL relevance, documentation, sensor redundancy, and integration options, while the remaining reviews explain the strengths and limitations of each option. Product prices and availability change, so check the current listing before purchasing.
5.0Editor score

4.8Editor score
4.8Editor score
The comparison below organizes all ten controllers by their most important design attributes, including processor class, sensor support, firmware compatibility, connectivity, and mounting dimensions. It is designed to make the differences clear before you investigate the full reviews and verify fit for a particular airframe.



The KK 2.1.5 is the most explicitly purpose-built controller in this group for VTOL and V-tail aircraft, giving it a clear advantage for builders searching for a straightforward board rather than a general-purpose autopilot. It carries a 5.0 rating in the supplied data, and its listed capabilities include stability, self-leveling, and acrobatic flight. Those functions make it especially relevant to hobby pilots who want a controller designed around a defined aircraft configuration.
We may earn a commission when you buy through this link, at no additional cost to you.
The product information describes applications including model-aircraft competitions, aerial photography, and flight-skill demonstrations. It is also presented as suitable for enthusiasts interested in exploring customizable flight-control behavior and challenging maneuvers. For a hybrid VTOL project, that combination of stability assistance and aerobatic options can be useful during development, provided that the board, receiver configuration, and motor outputs are matched carefully to the airframe.
The main trade-off is transparency. Unlike the open-source platforms in this guide, the supplied KK listing does not detail a processor model, navigation sensor suite, connector layout, or supported autopilot firmware. That makes it less attractive for advanced autonomous missions or developers who need a documented software ecosystem. It is also important to verify electrical compatibility and output requirements before committing to a build, especially when mixing fixed-wing controls with multiple lift motors.
This is a strong choice for a budget-conscious pilot building a conventional VTOL or V-tail aircraft and wanting a board with flight modes and stability features named explicitly. It is less suitable when a project depends on sophisticated autonomous flight, extensive telemetry, or a broad selection of open-source development tools. For the stated use case, however, it provides focused functionality without the complexity of a full research-oriented autopilot stack.
Because VTOL and V-tail operation are central to the product description, the KK 2.1.5 removes much of the guesswork involved in choosing a generic board for those layouts. Confirm the airframe's control and motor arrangements against the seller's current documentation before wiring it.
Self-leveling and acrobatic modes make the controller approachable for hobby flying and development. They can also provide a useful foundation for learning how fixed-wing and vertical-thrust behavior differs.
We may earn a commission when you buy through this link, at no additional cost to you.
The COREWING F405 V2 is positioned for RC airplanes and drones, giving it broad relevance for custom aircraft projects. Its F405 naming is consistent with a modern flight-controller platform, but the supplied product information is extremely limited and does not explicitly identify VTOL operation, sensor hardware, firmware, or connector configuration. That limited documentation makes careful verification essential.
We may earn a commission when you buy through this link, at no additional cost to you.
Its strongest potential is as a board-level choice for a builder who already understands the surrounding ecosystem. F405 controllers are commonly associated with flexible multirotor and custom aircraft configurations, and the product title directly connects this unit with both RC airplanes and drones. Nevertheless, VTOL projects have exacting requirements, so the general drone compatibility statement should not be treated as proof that transition logic or every necessary output is available.
There is no customer rating in the supplied dataset, and no meaningful basis is provided for comparing reliability or setup complexity with the more extensively documented Pixhawk and compact stack options. Missing details may simply reflect an abbreviated listing rather than an absence of capabilities. Still, they make purchasing risk higher because a buyer cannot confirm the receiver protocols, sensor complement, PWM or serial outputs, voltage tolerance, or firmware support from the information shown.
The F405 V2 is most appropriate for an experienced builder willing to consult the current documentation and verify compatibility before assembly. It may fit a custom fixed-wing or multirotor project, but it should not automatically be selected for a hybrid VTOL craft based on the product title alone. If the seller confirms dual-mode outputs, adequate sensor inputs, and appropriate firmware support, it could become a viable custom-build component.
This controller is best approached as part of a documented custom platform rather than as a turnkey VTOL solution. Review the pinout, firmware instructions, and connection diagram before ordering.
The abbreviated listing leaves several important questions unanswered. Confirm VTOL outputs, sensor inputs, receiver protocols, and supply requirements directly before committing to the airframe.
We may earn a commission when you buy through this link, at no additional cost to you.
The PIX 2-12S is one of the clearest choices for builders who need a configurable VTOL and multirotor core board. It uses an STM32F405VGT6 main controller and includes an MPU6500 gyroscope, VCM5883L magnetometer, and LPS22HB barometer. That sensor combination provides the fundamental types of measurements needed for stable orientation, heading, and altitude-aware flight control.
We may earn a commission when you buy through this link, at no additional cost to you.
The board measures 39 by 39 by 12 millimeters and uses a 30.5 by 30.5 millimeter mounting pattern, making it compatible with many compact multirotor and VTOL frames. A GH1.25 connector supports GPS, SBUS, PPM, and CRSF receivers, while six-channel PWM output supports OneShot and DShot. The listed power range extends from two to twelve cells, which is unusually broad for a board of this class.
The package contains the motherboard, ribbon cable, and basic wiring, with the listing noting that absorbers may vary by batch. It excludes the ESC, so pilots must account for that cost and integration requirement in the aircraft design. It is also a board-level autopilot rather than a complete aircraft or all-in-one stack, which means software configuration, sensor placement, receiver setup, and output wiring remain the builder's responsibility.
This controller is a good match for a DIY VTOL project needing several receiver formats, a broad battery range, and a documented set of onboard sensors. It is less convenient for someone wanting a plug-and-play system. The lack of a supplied customer rating is a limitation, but the detailed hardware description makes the PIX 2-12S easier to evaluate than listings that offer almost no specifications.
Support for Mavlink, SBUS, PPM, and CRSF gives builders more freedom when selecting a radio link. The correct protocol still depends on the receiver and the firmware configuration being used.
The integrated gyroscope, magnetometer, and barometer cover several essential motion and environmental measurements. Careful placement and calibration remain necessary for reliable VTOL transitions.
We may earn a commission when you buy through this link, at no additional cost to you.
The Pixhawk 2.4.8 is a widely applicable open-source flight controller, and the supplied listing explicitly supports fixed-wing, multirotor, helicopter, boat, and car configurations. Its 4.8 rating and inclusion of GPS in the listed combo make it a compelling general recommendation for hybrid VTOL work where pilots want a familiar PX4 ecosystem rather than a narrowly specialized board.
We may earn a commission when you buy through this link, at no additional cost to you.
Hardware includes a 32F427 ARM Cortex-M4 processor, a 32-bit fail-safe coprocessor, and an MPU6000 three-axis accelerometer. It can operate as a master controller by connecting motors, servos, cameras, sensors, and a microcomputer, giving DIY builders considerable flexibility. The open-source design also allows secondary development, making the board relevant to hobbyists, researchers, and programmers who need to modify behavior.
Its chief disadvantage is that it is not a turnkey VTOL product. A pilot must assemble the system, follow the included quick-start guide, perform calibration, and configure the airframe and software for the intended vehicle. It also uses an older processor generation than the H743 options in this list. That does not make it unsuitable, but it may be less attractive for particularly compute-intensive future applications.
For builders seeking a clear, broad autopilot foundation, the Pixhawk 2.4.8 remains one of the strongest selections in this guide. The included GPS and clear multi-vehicle support simplify initial planning for a hybrid aircraft. It is especially well suited to pilots who value open-source community knowledge and secondary development opportunities over a compact racing-oriented form factor.
Support for fixed-wing and multirotor vehicles is ideal for hybrid configurations that must coordinate two different forms of flight. The selected firmware and airframe setup must still be configured for the exact transition behavior.
The platform's open-source nature is valuable for pilots who want to inspect, modify, or extend autopilot behavior. It also requires more deliberate configuration than a dedicated hobby controller.
We may earn a commission when you buy through this link, at no additional cost to you.
The F405 Wing Flight Controller is explicitly designed for fixed-wing drones with VTOL capability, making it one of the most thematically appropriate products in the guide. It supports Ardupilot firmware and is described as configurable and monitorable through an app, combining a dedicated wing orientation with a familiar open-source flight ecosystem.
We may earn a commission when you buy through this link, at no additional cost to you.
Use of the F405 processor class is intended to provide fast and stable control while processing the different demands of fixed-wing and vertical-flight phases. The listing describes compatibility with numerous fixed-wing models, a lightweight and compact form, and a user-friendly setup with extensive features. These are appealing qualities for builders who want a wing-specific board without abandoning ArduPilot's customization environment.
The supplied data does not disclose the board's dimensions, mounting pattern, sensor complement, receiver protocols, output count, or supported power range. Consequently, physical fit and electrical integration must be checked carefully. The phrase “APP control” also needs interpretation carefully: mobile access may depend on a particular companion app, telemetry link, and software version, rather than being a fully self-contained feature of the board.
This controller is a strong candidate for a fixed-wing VTOL project that prioritizes wing-specific design and ArduPilot support. It may be particularly attractive to builders who want app-based parameter work without carrying the size of a conventional research autopilot. The unknown hardware details prevent it from taking the top recommendation, but they do not undermine its clear purpose within a hybrid VTOL build.
By targeting fixed-wing drones with VTOL capability, the controller offers a more specialized starting point than a generic multirotor board. Verify that its outputs and firmware parameters match the airframe.
App control can simplify monitoring and parameter changes, provided the required software and telemetry hardware are supported. Check the current compatibility details before relying on mobile setup.
We may earn a commission when you buy through this link, at no additional cost to you.
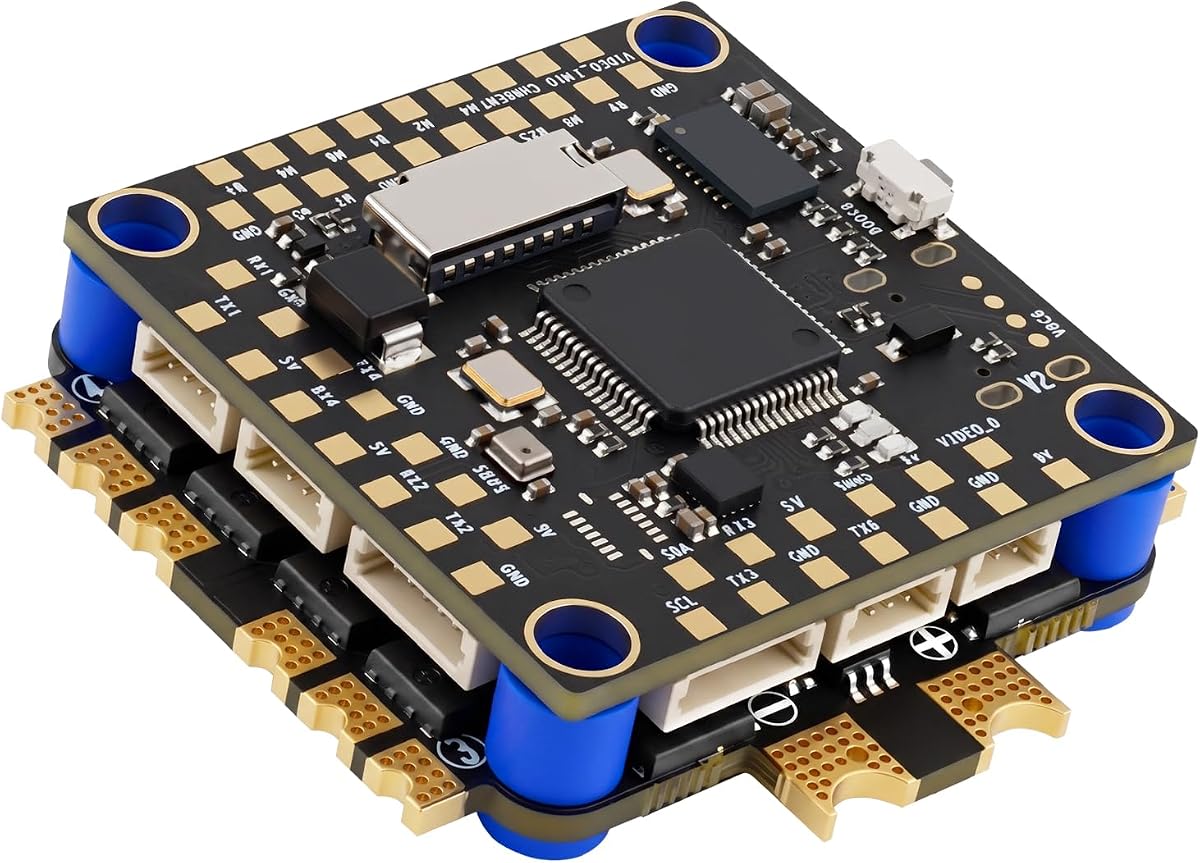
The CORVON H743 60A is a feature-rich flight-controller-and-ESC stack built around an STM32H743 processor operating at 480MHz. It includes dual BMI088 and BMI270 IMUs, a compass, a barometer, seven UART ports, ten PWM outputs, CAN, I2C, and OSD support. This combination gives a hybrid VTOL builder substantial room for telemetry, receivers, GPS, and other peripherals.
We may earn a commission when you buy through this link, at no additional cost to you.
Its matching 60A 32-bit four-in-one ESC supports two-to-eight-cell lithium-polymer batteries, provides 60A continuous current per channel, and is stated to deliver burst current above 80A. The 30.5 by 30.5 millimeter mounting pattern fits many common multirotor frames, while the combined weight of the ESC and controller is listed as 23.2 grams. Firmware support includes Betaflight, PX4, INAV, and ArduPilot.
The integrated ESC is convenient for compact builds, but it also means the pilot must match the stack's battery range and current handling to the motors, propeller loads, and wiring. The 60A version is intended for higher current demands than the 50A alternative, though published continuous ratings are not a substitute for a proper motor and power-system calculation. Its racing and FPV origins also mean VTOL suitability depends on firmware configuration and available control outputs.
This is a compelling option when a builder prioritizes processing power, port expansion, flexible firmware, and an integrated ESC. It is less ideal for a large conventional fixed-wing craft where a compact receiver and motor mixer would be more natural. For custom multirotor or hybrid VTOL experiments with substantial auxiliary electronics, however, its connectivity makes it a strong foundation.
Seven UARTs, ten PWM outputs, CAN, I2C, and OSD support create a generous connection budget. This is useful when GPS, telemetry, camera control, and receiver equipment all need to coexist.
Pairing the controller with a 60A 32-bit ESC reduces the number of separate components. Match the stack to the actual motor current, battery configuration, and frame's thermal limits.
We may earn a commission when you buy through this link, at no additional cost to you.
The CORVON H743 50A combines a 480MHz STM32H743 controller with a 50A four-in-one eight-bit ESC. It includes two megabytes of flash memory, dual BMI088 and BMI270 IMUs, a compass, a barometer, and extensive connectivity through seven UARTs, ten PWM outputs, CAN, I2C, and OSD. It supports Betaflight, ArduPilot, PX4, and INAV.
We may earn a commission when you buy through this link, at no additional cost to you.
Compared with the 60A version, this stack supports two-to-six-cell batteries rather than two-to-eight. Its ESC provides 50A continuous current per channel and supports high-frequency PWM, DShot, and OneShot for throttle response. The entire flight-controller-and-ESC combination weighs 21.5 grams, and the 30.5 by 30.5 millimeter mounting pattern is common across compact drone frames.
An eight-bit ESC is a meaningful distinction in a performance-oriented build. It can still provide responsive motor control, but builders should assess whether the motor load and desired performance justify moving to the 32-bit option. The H743 controller itself is still powerful, so this stack is better understood as a balanced package in which the ESC is tailored to moderate current demands rather than maximum racing loads.
For a lightweight hybrid VTOL build that fits within a six-cell electrical system, the CORVON H743 50A offers strong processing capability and extensive expansion at a modest combined weight. It is especially relevant to pilots already familiar with compact stacks and multi-firmware workflows. As with any integrated ESC, correct wiring, current planning, and thermal management are essential.
Combining the controller and four-in-one ESC can simplify assembly and save frame space. Check that the stack's current rating, protocol support, and battery range fit the selected motors and propellers.
Compatibility with Betaflight, INAV, PX4, and ArduPilot gives builders multiple development paths. Each platform has different configuration assumptions, especially for fixed-wing transitions.
We may earn a commission when you buy through this link, at no additional cost to you.
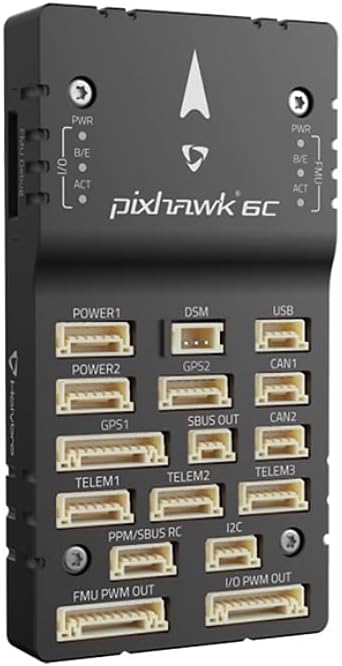
The Pixhawk 6C is the advanced autopilot option in this roundup, built around a 32-bit STM32H743 ARM Cortex-M7 processor running at 480MHz. It provides two megabytes of flash memory and one megabyte of RAM, enough processing headroom for sophisticated autonomous-aircraft algorithms and development work. It is supplied with PX4 Autopilot pre-installed and supports ArduPilot v4.3 or later for the listed M10 GPS.
We may earn a commission when you buy through this link, at no additional cost to you.
Redundant inertial sensing is one of its defining strengths. Bosch BMI055 and InvenSense ICM-42688-P IMUs provide duplicate motion measurements, while onboard heating resistors help maintain suitable operating temperature. The integrated vibration-isolation system is designed to reduce high-frequency airframe vibration and sensor noise, which is particularly valuable in VTOL aircraft where propulsion vibration can affect control reliability.
Its physical design is less compact than the 30.5-millimeter racing stacks. The plastic-case version measures 84.8 by 44 by 12.4 millimeters and weighs 34.6 grams, while the listing also references a more durable aluminum option at 59.3 grams. The larger footprint can be manageable in a hybrid airframe, but it must be planned around. The hardware-switchable PWM signal mode offers additional peripheral compatibility.
The Pixhawk 6C is the premium recommendation for serious VTOL, research, and autonomous-development projects that value redundancy and vibration control. Its pre-installed PX4 software reduces initial setup friction, while broad firmware support and substantial processing power provide long-term flexibility. It is the least convenient option for a tiny racing frame, but for a purpose-built hybrid aircraft, those constraints are often outweighed by sensor quality and robustness.
Two inertial sensor families allow the system to cross-check motion data, adding resilience for research and autonomous projects. Correct installation and vibration control remain essential for realizing the benefit.
Pre-installed PX4 means a builder can focus on airframe configuration and sensor integration immediately. ArduPilot support expands options for teams that prefer that software environment.
We may earn a commission when you buy through this link, at no additional cost to you.
The AERO SELFIE F405NC is a compact controller-and-ESC stack centered on an STM32F405 processor running at 168MHz. It has dual BMI42688 IMUs, a DPS310 barometer, and an interface advertised for O3 and O4 AIR equipment. Its 4.4 rating gives it the second-highest supplied numerical rating among the compact stacks, making it a credible option for compact hybrid and multirotor projects.
We may earn a commission when you buy through this link, at no additional cost to you.
The board includes six UART ports, ten PWM outputs, I2C, and OSD support. It works with Betaflight, INAV, and ArduPilot, and its 30.5 by 30.5 millimeter mounting pattern fits many common frames. The flight controller and ESC together weigh 23.2 grams. Compatibility with O3 and O4 AIR interfaces can be valuable when the aircraft carries a digital FPV system, although the necessary cable or adapter still needs to be confirmed.
The ESC is described in the title as 60A and 8-bit, while the detailed bullet identifies it as a 45A 4-in-one 8-bit ESC and states a 60A continuous rating per channel. This inconsistency in the supplied description should prompt buyers to check the current seller's specifications. The electrical system, protocol support, and actual current rating all need confirmation before the stack is used with high-load motors.
The F405NC is a good fit for a compact project that values multiple telemetry options and modern digital-video interfaces. Its 168MHz processor and eight-bit ESC place it below the H743 and 32-bit ESC alternatives for compute-intensive work, but it can still serve capable custom aircraft. Its main appeal is the combination of compactness, dual IMUs, broad firmware support, and O3 or O4 AIR integration.
The advertised O3 and O4 AIR interface is useful for compact FPV-oriented builds. Confirm the exact connector, cable, and power requirements for the selected video system.
The F405 processor provides a well-known platform with broad community familiarity. It is a practical option when the aircraft does not require the processing headroom of an H743 controller.
We may earn a commission when you buy through this link, at no additional cost to you.
The AERO SELFIE H743 combines a 480MHz STM32H743 processor, dual BMI088 and BMI270 IMUs, and a 60A 32-bit four-in-one ESC in a 30.5 by 30.5 millimeter package. It supports two-to-six-cell batteries and provides 60A continuous current per channel with burst current stated above 80A. The total weight of the controller and ESC is listed as 23.2 grams.
We may earn a commission when you buy through this link, at no additional cost to you.
Connectivity is a major strength. Seven UART ports, ten PWM outputs, CAN, I2C, and OSD support make it possible to add receivers, GPS, telemetry, camera control, and other peripherals. Firmware compatibility includes Betaflight, PX4, INAV, and ArduPilot, giving a hybrid VTOL builder several possible configuration paths. The 32-bit ESC also offers a more modern motor-control architecture than eight-bit compact alternatives.
Its 3.7 supplied rating is lower than those of the other rated selections, so buyers should treat the current customer feedback as an important part of the decision. The product data contains some potentially confusing wording around the ESC model and current description, making it sensible to verify the exact specification on the live listing. The system is also limited to six-cell batteries, which is a constraint for some VTOL designs.
Despite the rating caveat, the technical package is attractive for pilots who want H7 processing and a modern ESC in a compact stack. It fits multi-rotor and FPV platforms particularly well and can contribute to a custom hybrid build when ArduPilot or PX4 configuration is used. For a conventional larger fixed-wing airframe, the compact racing-oriented format and modest battery range may be less appropriate.
The 32-bit ESC and high-current rating suit responsive motor control. Verify propeller, motor, and wire sizing so the theoretical stack rating translates into a reliable aircraft power system.
Seven UARTs and ten PWM outputs leave ample room for auxiliary systems. That makes the stack practical for VTOL experiments that require more than a basic receiver and motor mixer.
We may earn a commission when you buy through this link, at no additional cost to you.
A hybrid VTOL flight controller must bridge fixed-wing and multirotor control requirements, so compatibility, sensor quality, and firmware matter more than processor marketing alone. The following factors help narrow the field before you commit to a board or integrated stack.
Start with the aircraft's control architecture. A VTOL-capable autopilot must coordinate separate fixed-wing surfaces, lift motors, throttle, and a reliable transition sequence. Some boards merely fit multirotors or airplanes, while others are explicitly designed for fixed-wing VTOL. The KK 2.1.5 and F405 Wing are described with direct VTOL positioning, while the PIX 2-12S and Pixhawk platforms support VTOL or multirotor applications. Review output assignments and firmware parameters for your exact wing and tail configuration before ordering.
Decide whether you want PX4, ArduPilot, INAV, Betaflight, or a dedicated hobby controller. PX4 and ArduPilot are prominent in the autonomous and fixed-wing VTOL ecosystem, while the compact stacks offer broader platform compatibility. Dedicated controllers can simplify certain manual flying or development projects but may offer less transparency and customization. Consider the documentation, ground-control tools, parameter workflows, and community resources that match your experience level.
Stable VTOL transitions require accurate motion, heading, and altitude measurements. The PIX 2-12S includes a gyroscope, magnetometer, and barometer. Pixhawk 6C adds redundant inertial sensors, temperature control, and integrated vibration isolation. The compact H743 stacks list dual IMUs, a compass, and a barometer. Magnetometers can be affected by motor current and ferrous hardware, while barometers respond to airflow and pressure changes, so placement and calibration are as important as the component list.
Count the receiver, ESC, servo, GPS, telemetry, companion-computer, camera, and OSD connections the aircraft will need. The PIX 2-12S supports several receiver formats, while the H743 boards provide seven UARTs and ten PWM outputs. VTOL aircraft often need more outputs than ordinary multirotors because they combine control surfaces with lift motors. Leave expansion capacity for future receivers or payloads, and verify connector types and voltage levels before assembly.
Mounting pattern and clearance determine whether a board can fit without changing the airframe. The compact stacks use a 30.5 by 30.5 millimeter pattern, the PIX 2-12S measures 39 by 39 millimeters with the same hole spacing, and the Pixhawk 6C has a substantially larger footprint. Also account for cables, vibration damping, antennas, and airflow. On a fixed-wing aircraft, every saved gram can improve endurance and payload capacity.
Integrated ESC stacks must be matched to the battery configuration, motor current, propeller load, and wiring. The CORVON 60A version supports two-to-eight cells, while the 50A version and AERO SELFIE H743 support two-to-six cells. The Pixhawk 2.4.8 does not arrive as an integrated stack. Continuous current ratings are not the same as realistic all-components thermal limits, so calculate expected draw and use appropriate connectors and protection.
The STM32H743 boards operate at 480MHz and offer more headroom than the 168MHz F405 and F405NC platforms. Extra processing can benefit autonomous algorithms and complex configurations, but it is not the only reliability factor. A correctly calibrated and mechanically stable lower-speed system can outperform a theoretically stronger board installed too close to vibration sources. Choose processing power based on the firmware, payload, and future development plan.
A flight controller is only as dependable as its wiring guide, parameter documentation, and calibration process. The Pixhawk 2.4.8 includes a quick-start guide, while the Pixhawk 6C arrives with PX4 pre-installed. Some other listings provide less detailed information and have no supplied customer rating. Review the current documentation, seller support, customer feedback, and community resources before assembling a safety-critical aircraft.
Before installing the controller, identify every receiver, ESC, servo, GPS, telemetry device, and companion-computer connection. Create a wiring diagram and verify voltage levels, signal protocols, pin functions, and current requirements. Mount the board on suitable vibration isolation, keep the magnetometer away from high-current wiring and magnets, and position the barometer where it can sense ambient pressure without direct propeller wash.
Install the appropriate firmware and perform the complete calibration sequence in a safe environment. Begin with receiver input tests, output monitoring, motor direction checks, and low-power hover or taxi tests. For a hybrid aircraft, confirm that the fixed-wing surfaces, vertical thrust motors, throttle range, and transition behavior are correctly assigned. Record the configuration and retain a known-good backup before expanding to autonomous missions or adding payloads.
Care for the controller by keeping it protected from moisture, dust, carbon dust, and physical impact. Inspect connectors, solder joints, mounting hardware, and vibration isolators regularly, particularly after crashes or hard landings. Recheck sensor calibration after moving the airframe, changing the motor system, or altering the center of gravity. Update firmware cautiously, understand the changes, and retest every essential function after an update.
It can be if the controller has enough outputs for the vertical motors and fixed-wing control surfaces, suitable sensor inputs, and firmware that supports the required transition logic. A purpose-built VTOL controller or an established PX4 or ArduPilot platform is generally easier to configure than a basic racing board. Always verify the output count, mixing features, and autopilot behavior for the specific airframe.
Both are capable open-source autopilot ecosystems, and the better choice depends on your ground-control software, workflow, and existing experience. PX4 is pre-installed on the Pixhawk 6C and included in the Pixhawk 2.4.8 listing, while the F405 Wing explicitly supports ArduPilot. Review current documentation, hardware support, and transition examples for each platform before deciding.
The correct range depends on the aircraft's motors, propellers, battery chemistry, and performance requirements. The listed boards range from two-to-six-cell systems to the two-to-eight-cell CORVON 60A stack, while the PIX 2-12S accepts two through 12 cells. Choose a controller whose electrical range matches the intended battery and verify that all ESCs and regulators support the same configuration.
Dual inertial sensors provide redundant motion measurements that can help reveal sensor faults and improve confidence in attitude and motion data. They are especially attractive in aircraft with powerful motors and changing vibration conditions. Redundancy does not eliminate the need for good isolation, calibration, wiring, and airflow because both sensors still need clean data.
A controller-only unit offers more freedom to match ESCs to a large fixed-wing airframe and provides broader electrical flexibility. An integrated stack simplifies a compact multirotor build, reduces component count, and can make wiring easier. Ensure the stack's mounting pattern, current rating, battery range, motor protocols, and firmware support all match the aircraft.
Look for a protocol already supported by your radio system and the intended firmware. The PIX 2-12S supports Mavlink, SBUS, PPM, and CRSF, which gives considerable flexibility. Some other listings do not disclose receiver support, so consult the current wiring documentation before buying. Also check whether an external receiver is included.
Reserve the board's stated dimensions plus room for connectors, cable bends, vibration damping, and access to installation hardware. The PIX 2-12S is 39 by 39 millimeters, the compact stacks use a 30.5 by 30.5 millimeter mounting pattern, and the Pixhawk 6C has a larger 84.8 by 44 millimeter footprint. A CAD layout or physical mock-up can prevent costly redesigns.
Controllers with PX4, ArduPilot, INAV, or extensive receiver and telemetry support can participate in autonomous systems, but hardware alone does not guarantee mission readiness. A reliable GPS, correctly calibrated sensors, mission-compatible hardware, telemetry, failsafe procedures, and thorough testing are required. Test every phase of flight without a pilot in manual control before relying on autonomous operations.
The KK 2.1.5 stands out as the focused, budget-oriented choice for VTOL and V-tail hobby builds, while the Pixhawk 2.4.8 is the most versatile open-source recommendation for pilots who want a GPS-equipped autopilot across multiple vehicle types. The Pixhawk 6C takes the premium position with its H743 processor, redundant IMUs, vibration isolation, and pre-installed PX4. Each serves a different level of aircraft complexity and pilot involvement.
Prioritize the requirements that cannot be changed easily: VTOL-specific firmware behavior, output count, sensor placement, mounting clearance, and electrical compatibility. Processor speed is important, but a well-calibrated system with clean sensor data and correct wiring is more valuable than raw specifications. Compact stacks are useful for experimental multirotor-based hybrids, while dedicated wing controllers and Pixhawk platforms suit deeper fixed-wing and autonomous development.
Finally, check the current listing, technical documentation, package contents, and customer feedback before purchasing, because specifications and prices can change. Confirm every connector, firmware version, sensor, mounting dimension, and battery requirement against your planned aircraft. A careful compatibility check is the most practical way to avoid replacing a capable flight controller after the build is already underway.